

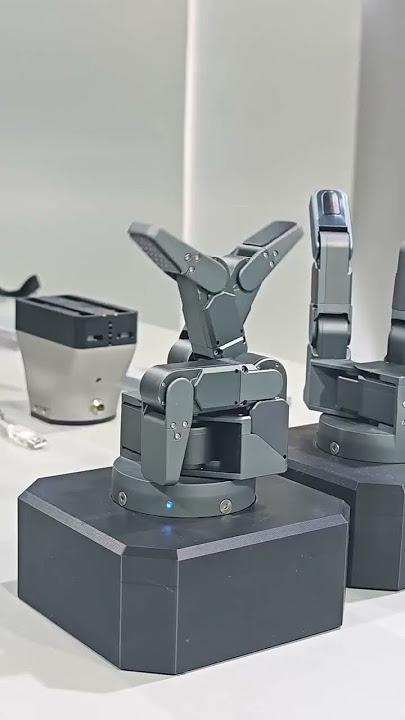
UDH-3-7-50
UDH-3-7-50 three-finger dexterous hand
Three-finger hand built for general grasping with 7 active degrees of freedom — three on the thumb, two each on index and middle. Direct-drive frameless motors in anti-backlash joint modules give 50 N rated fingertip force, 15 kg payload, ±0.02 mm fingertip repeatability and 1.2° joint backlash. 900 g, 89 × 84 × 105 mm, 24–72 V, RS-485, CAN FD and EtherCAT with position, velocity and force control loops. Ships with SDK, ROS2, Isaac and MuJoCo support plus a high-precision URDF model. Optional fingertip tactile sensing to 0.01 N normal force.
Specifications
UDH-3-7-50- Number of fingers
- 3
- Overall dimensions
- 89 × 84 × 105 mm
- Weight
- 900 g
- Active DOF
- 7 (thumb ×3, index ×2, middle ×2)
- Joint type
- Direct-drive rotary joints ± 90°
- Motor type
- Direct-drive frameless motors
- Rated joint speed
- 66 rpm / 50 rpm
- Rated joint torque
- 2.5 N·m / 5 N·m
- Rated fingertip force
- 50 N
- Payload capacity
- 15 kg
- Supply voltage
- 24 – 72 V
- Interfaces
- RS-485 / CAN FD / EtherCAT
- Control modes
- Position, velocity and force loops
- Development support
- SDK, ROS2, Isaac, MuJoCo; URDF model
- Fingertip repeatability
- ± 0.02 mm
- Grasping lifetime
- ≥ 1,000,000 cycles
Model Variants
| Model | Number of fingers | Overall dimensions | Weight |
|---|---|---|---|
| UDH-3-7-50 | 3 | 89 × 84 × 105 mm | 900 g |