

DH-5-6
DH-5-6 dexterous hand
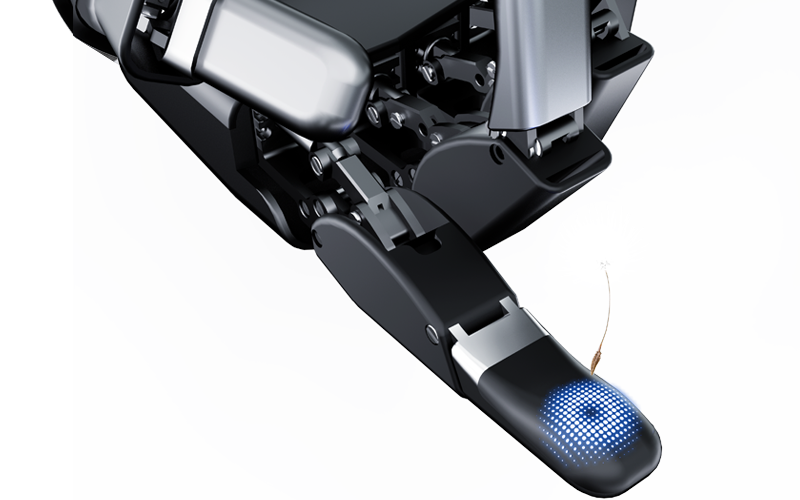
Five-finger anthropomorphic hand engineered for industrial deployment: 6 active and 11 total degrees of freedom, 80 N five-finger grip, 25 N fingertip force, 10 kg lifting load, 0.8 s cycle time and a grasping life above one million cycles. 790 g, 24 V DC, Modbus-RTU over RS485. Optional array tactile sensors on fingertips and palm with sub-0.62 ms response and 2.5 kPa⁻¹ sensitivity. Internal grasp-direction anti-collision as standard. For education and research, motion-capture training, data-collection centres and assisted care.
Specifications
DH-5-6- Active / total DOF
- 6 / 11
- Cycle time
- 0.8 s
- Service life
- ≥ 1,000,000 cycles
- Lifting load capacity
- 10 kg
- Five-finger grasping force
- 80 N
- Single fingertip force
- 25 N
- Operating voltage
- 24 V DC ± 10%
- Communication
- Modbus-RTU / RS485 custom protocol
- Safety function
- Anti-collision buffering during inward clench
- Single hand weight
- 790 g
- Tactile sensing (optional)
- Fingertip + palm array, < 0.62 ms response, 2.5 kPa⁻¹, 0–2 MPa, > 5,000,000 cycles
Model Variants
| Model | Active / total DOF | Cycle time | Service life |
|---|---|---|---|
| DH-5-6 | 6 / 11 | 0.8 s | ≥ 1,000,000 cycles |